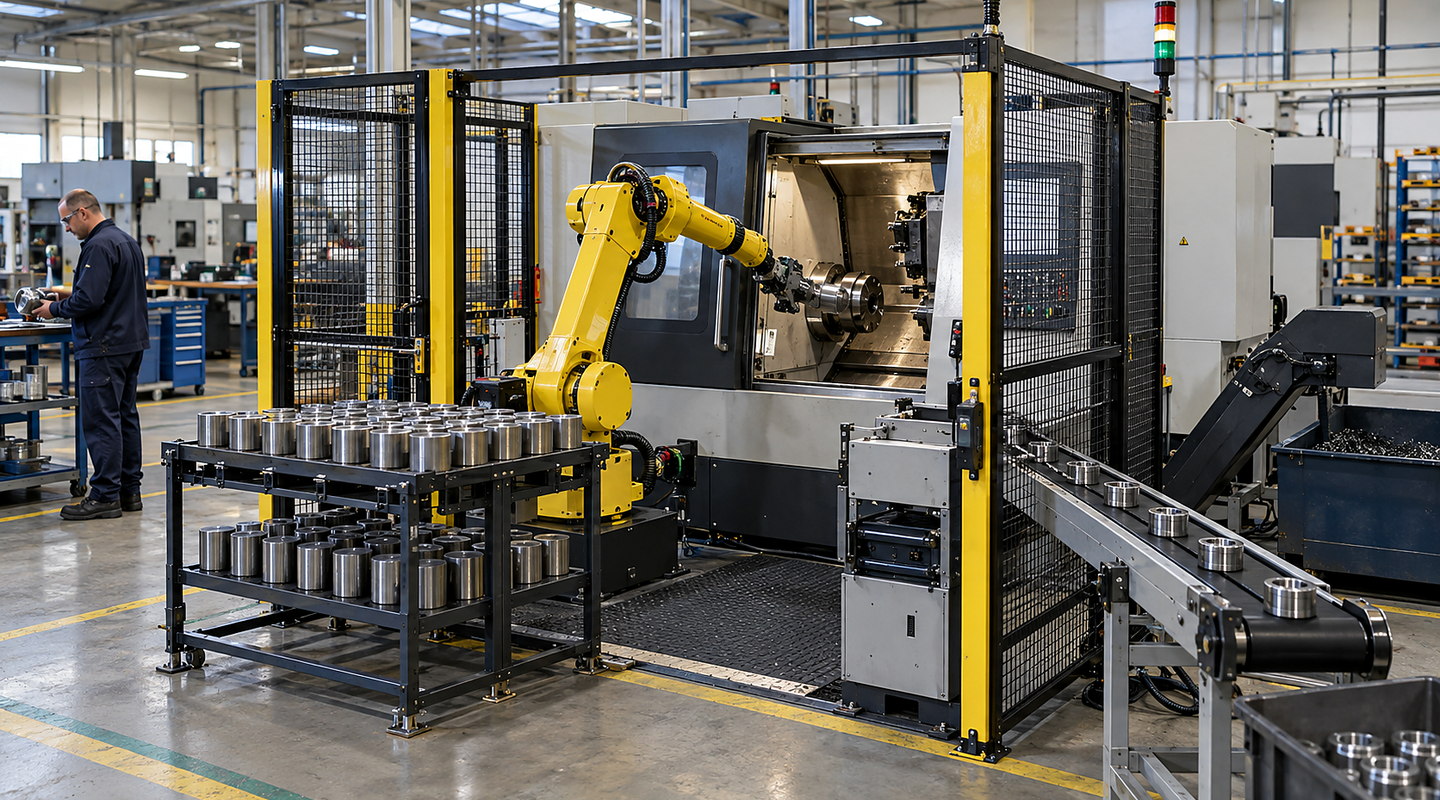
Robot Offline Programming: How the Process Works
Follow the operating sequence for robot offline programming, from preparing the input and controlling the main task to handling exceptions and checking results.
Robot offline programming starts with a model of the proposed cell: its geometry, robot, tooling, fixtures and process points. Review the intended sequence against that model, record what it assumes, and identify the positioning, interface and operating checks still needed on the physical cell.
Separate a model review from evidence that the installed cell meets its requirements. Use the specification checklist to define inputs and scope, then agree acceptance evidence for the model and the eventual installation.
Understand the complete route from input to accepted output — Robot Offline Programming
Follow the part through the intended sequence and identify which steps are represented in the model. Keep geometry, tooling, process points and interface assumptions traceable to their supplied revisions. A result that depends on an unmeasured location or an assumed machine response remains a question for physical confirmation.
Discuss your application

Four clear stages for robot offline programming
At each stage, record the information used, the question being reviewed and the evidence needed before the next decision. Keep model observations separate from measurements and checks on the real cell.
- 01
Observe the Current Process and Collect Representative Samples
Collect the cell layout, robot and tooling data, fixture drawings and process points alongside representative parts and cycle observations. Mark missing information, supplied revisions and differences between the drawings and the proposed or existing cell.
- 02
Prove Handling and Process Risks in a Focused Feasibility Trial
Use the proposed model and focused feasibility work to review the intended sequence and difficult part or presentation cases. State what was represented, what was assumed and which questions need a physical trial; a modelled sequence alone does not establish the production result.
- 03
Design and Build the Complete Guarded Cell
Resolve the layout, tooling and machine or line interfaces against the reviewed sequence. Agree who confirms the physical positions, operating modes and interface behaviour on site, and how changes to the installation will be reflected in the model and programme information.
- 04
Run Agreed Scenarios and Support Production Ramp-Up
Review the agreed model scenarios and complete the planned checks on the physical cell under the application-specific test plan. Record results, adjustments and outstanding assumptions, including complete-cycle observations and the assessed recovery and changeover arrangements.
Decisions and results stay connected
| Stage | What happens | What you can review |
|---|---|---|
| Observe the Current Process and Collect Representative Samples | Confirm the requirements for robot simulation and offline programming, the operating range and the definition of a good result. | Your samples, current information and any points that still need confirming. |
| Prove Handling and Process Risks in a Focused Feasibility Trial | Compare workable methods using part, product and process variation for robot simulation & offline programming and arrival pattern and presentation from your real production. | The trial method, observations and reason for the recommended route. |
| Design and Build the Complete Guarded Cell | Resolve required cycle and production pattern, tooling, sensing and process interfaces and the physical, control, safety and data connections. | The agreed layout, line connections and any changes from the proposal. |
| Run Agreed Scenarios and Support Production Ramp-Up | Check normal, difficult and fault conditions before your team takes over the system. | Results for operator access, recovery and changeover and run-off criteria and production evidence, plus actions and operating information. |
Keep connected responsibilities clear
Your final robot offline programming scope must also account for operator access, recovery and changeover, run-off criteria and production evidence, current regulations and the conditions at your site.
- Cycle time depends on the complete process rather than robot speed alone.
- Part presentation, tolerances and recovery cases must be included in feasibility work.
- Collaborative operation or automatic handling cannot be assumed safe without an application assessment.