Understand your requirement
Review part, product and process variation for robot simulation & offline programming, arrival pattern and presentation, and required cycle and production pattern using your samples, drawings and production observations.
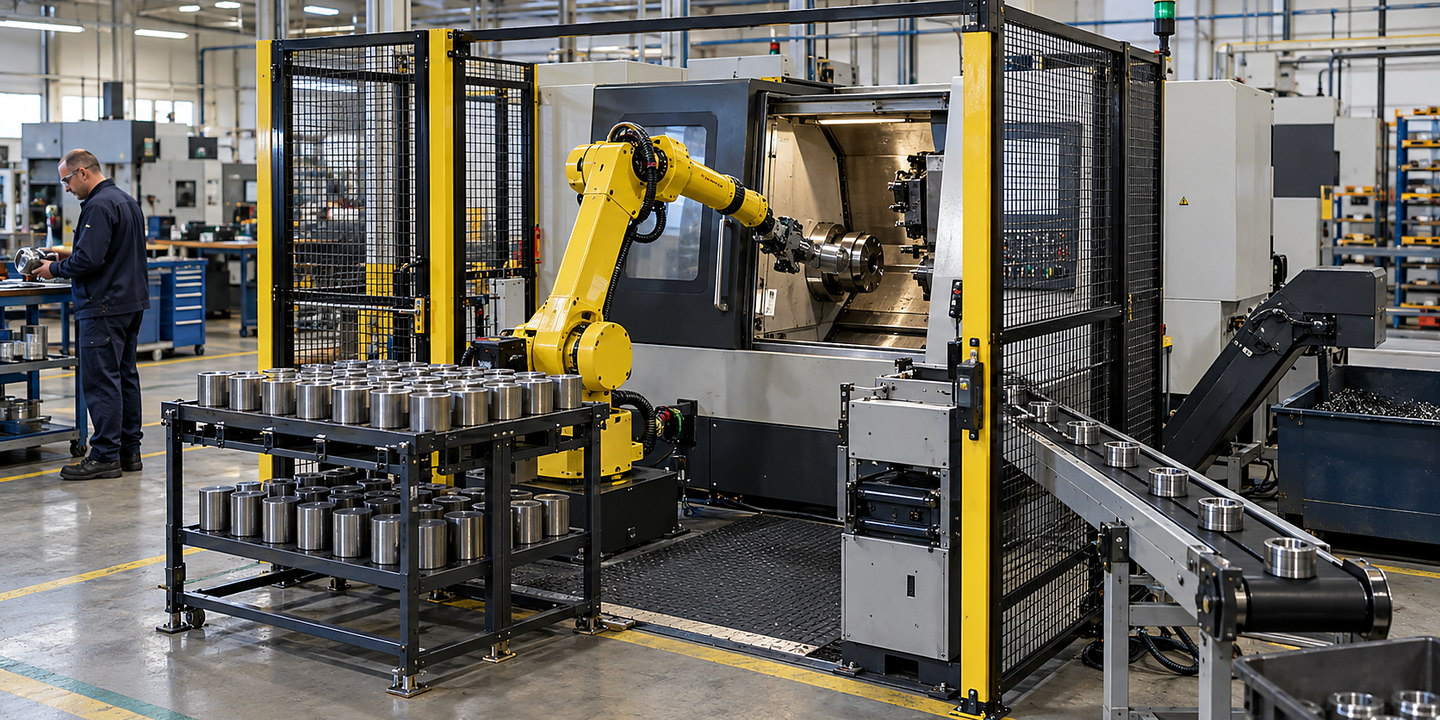
Compare practical options for robot simulation and offline programming, including what each route needs, where it fits and what to check before you decide.
The right solution for robot offline programming is the simplest system that reliably handles your stated duty, line connections and expected exceptions.
Plan robot offline programming around your parts, process, cycle time, tooling, recovery and acceptance criteria. Discuss the highest-risk feasibility questions with Oxford Industrial Automation.
Plan robot offline programming around your parts, process, cycle time, tooling, recovery and acceptance criteria. Discuss the highest-risk feasibility questions with Oxford Industrial Automation. When you compare solutions, check how each option handles part, product and process variation for robot simulation & offline programming, arrival pattern and presentation and your surrounding line.
Discuss your application

Review part, product and process variation for robot simulation & offline programming, arrival pattern and presentation, and required cycle and production pattern using your samples, drawings and production observations.
Run focused trials for robot offline programming so you can see why an option is recommended or ruled out.
Resolve tooling, sensing and process interfaces, operator access, recovery and changeover, controls, safety, operator access and maintenance before site work.
Check run-off criteria and production evidence in normal, difficult and fault conditions, then agree training and support for your team.
Typical support: feasibility study, sample trials, cell design, offline build, integration and production ramp-up.
| Approach | Often suitable when | Watch for |
|---|---|---|
| Robot Offline Programming | You need a dedicated solution for a clearly defined duty, product or part range and line interface. | Cycle time depends on the complete process rather than robot speed alone. |
| Purpose-Built Mechanical Automation for a Stable, Very High-Volume Task | The production task and part range are stable enough to assess purpose-built mechanical automation against the required sequence and output. | Check tooling, changeover, line connections and recovery requirements before committing to a fixed production arrangement. |
| Operator-Assisted Fixtures where Flexibility or Business Case Does Not Support a Robot Cell | Product variation, operator judgement or the business case makes operator-assisted fixtures a practical production route to assess. | Assess operator access, ergonomics, repeatability and the complete working sequence for the proposed fixture arrangement. |